Depth Reconstruction from a Single Image with Deep Neural Networks
March 20, 2023
project lapse time: 2021-07-26 - 2021-08-27As part of my academic project at
MIT summer online course,
I had the opportunity to lead a
team that explored the use of deep
neural networks for depth reconstruction
from a single image. Our goal was to
develop an accurate and efficient system
that could predict the depth of a scene
from a single input image using deep
learning techniques.
Project Overview
Depth reconstruction from a single image is
a challenging task in computer
vision that requires the use of complex
algorithms and machine learning techniques.
Our team decided to focus on using deep
neural networks to solve this problem.We used the KITTI dataset,
which consists of stereo image pairs,
along with their corresponding ground truth
depth maps, as our training data.
We preprocessed the data to extract the
necessary features and fed it into a deep
neural network built using the TensorFlow
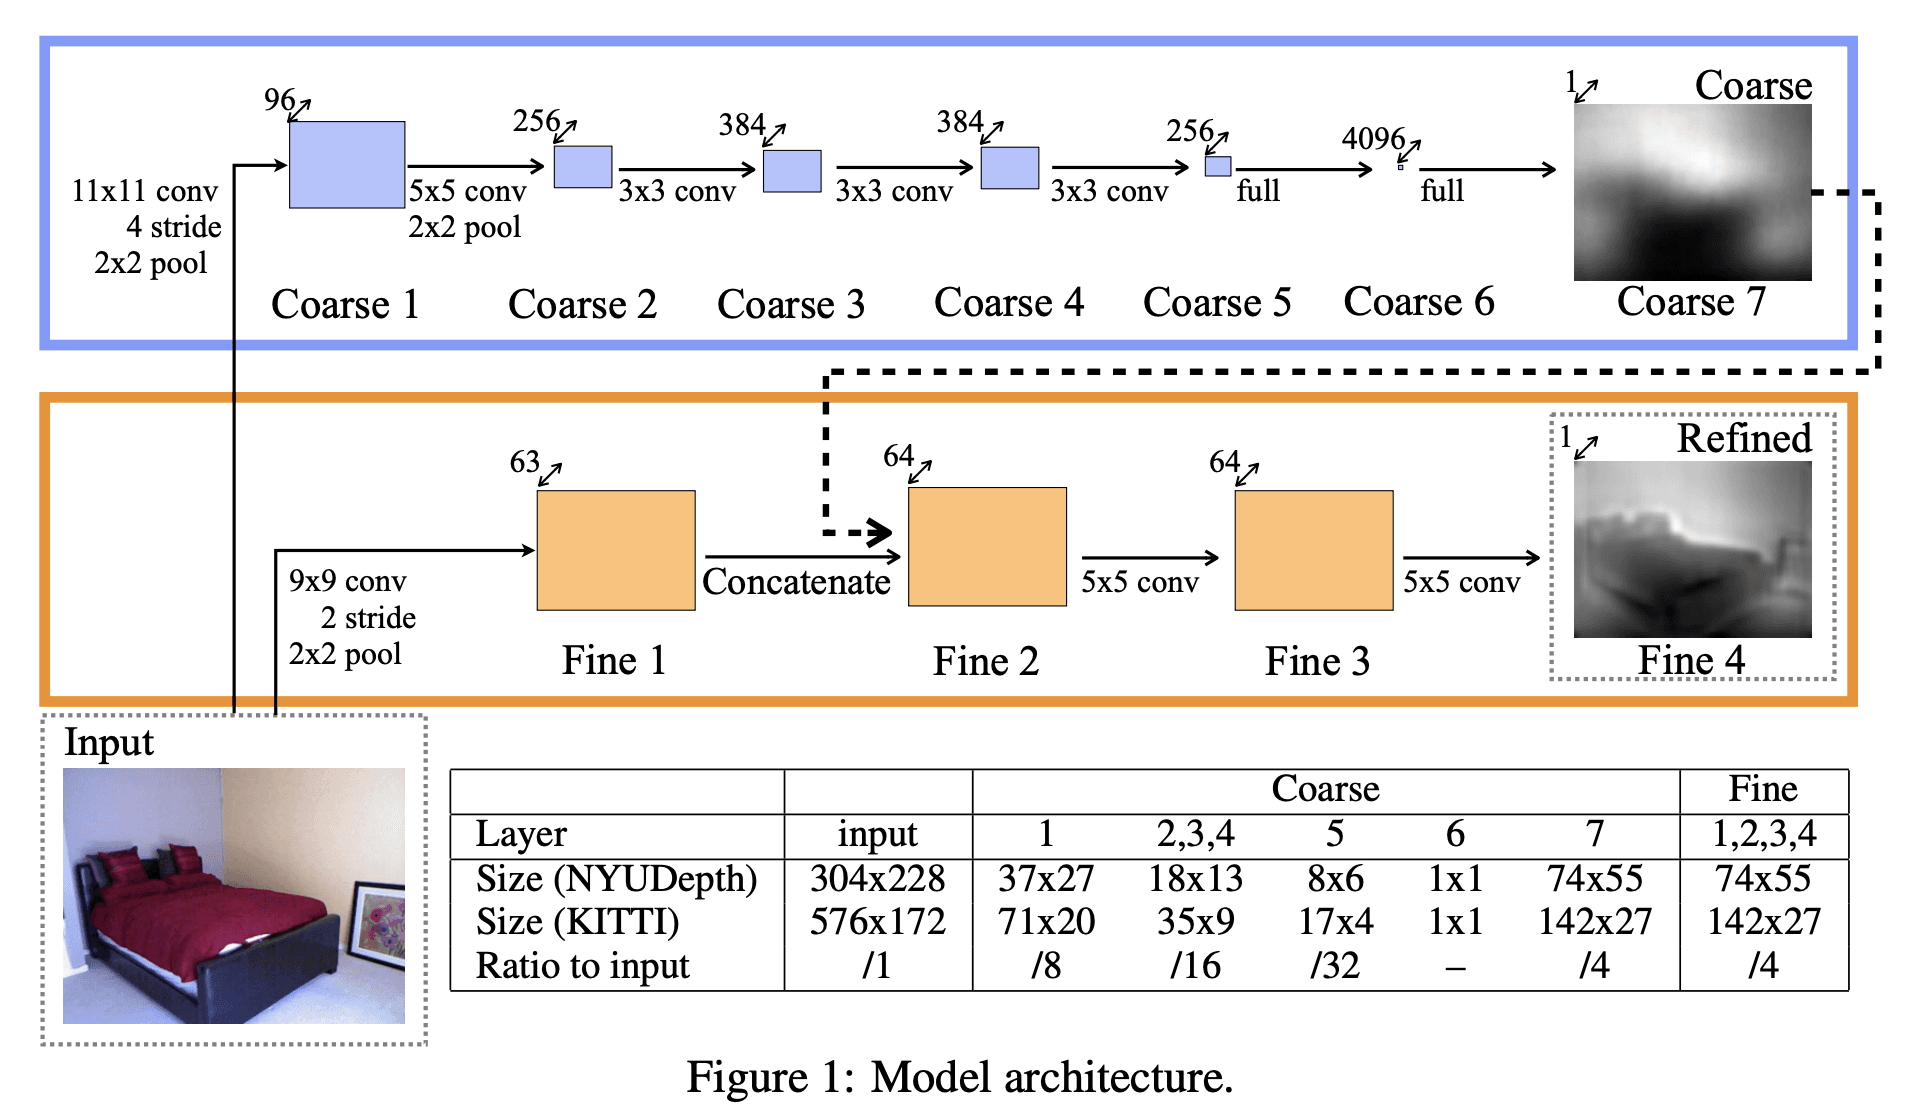
framework.To train the network, we used the
seminal work
of Eigen et al. as a starting point.They proposed a deep learning
architecture that achieved
state-of-the-art performance on
the task of depth reconstruction
from a single image. We modified
this architecture to improve its
accuracy and efficiency.
Technical Implementation
We implemented the deep
neural network using TensorFlow and
trained it on Google Colab for group
collaboration. We used a combination
of convolutional and fully connected
layers to extract features from the
input image and predict the depth map.We experimented with
different loss functions,
including mean squared error and
binary cross-entropy, and fine-tuned
the hyperparameters to achieve optimal
performance. We also implemented data
augmentation techniques such as random
flipping and rotation to improve the
robustness of the model.
Results
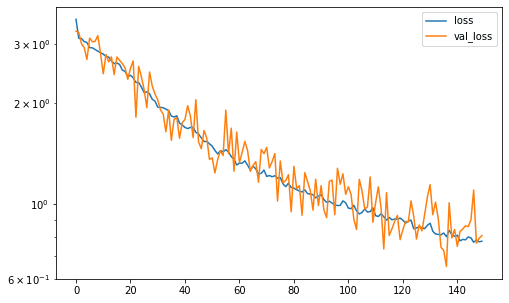
Our model achieved a training loss of 0.7759
and a validation loss of 0.8067
on the KITTI dataset
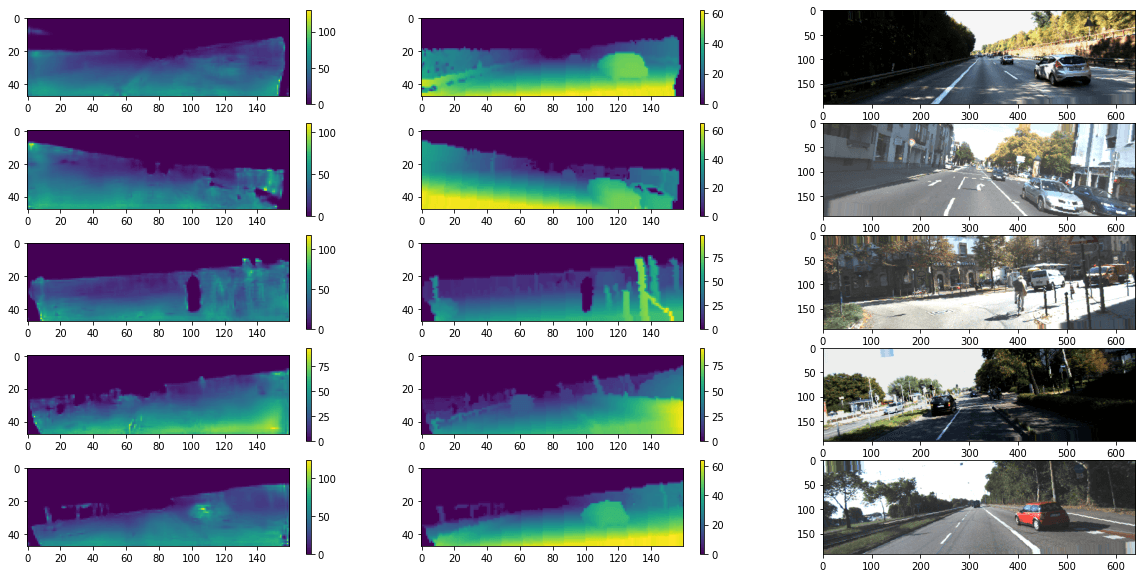
over 150 epochs of training.We also visualized the depth maps
generated by our model and compared
them to the ground truth depth maps.
Our results demonstrated that our model
was able to accurately predict the depth
of a scene from a single image.
Conclusion
In conclusion, our project demonstrated
the potential of deep neural networks for
depth reconstruction from a single image.
We were able to successfully train a deep
neural network to predict the depth of a
scene from a single image
on the KITTI dataset using the
TensorFlow framework and a modified version
of the deep learning architecture proposed
by Eigen et al.Our project has several potential applications,
including autonomous driving, robotics,
and augmented reality. We believe that the
techniques and insights gained from this
project will be valuable for future research
in computer vision and machine learning.